Fruit first
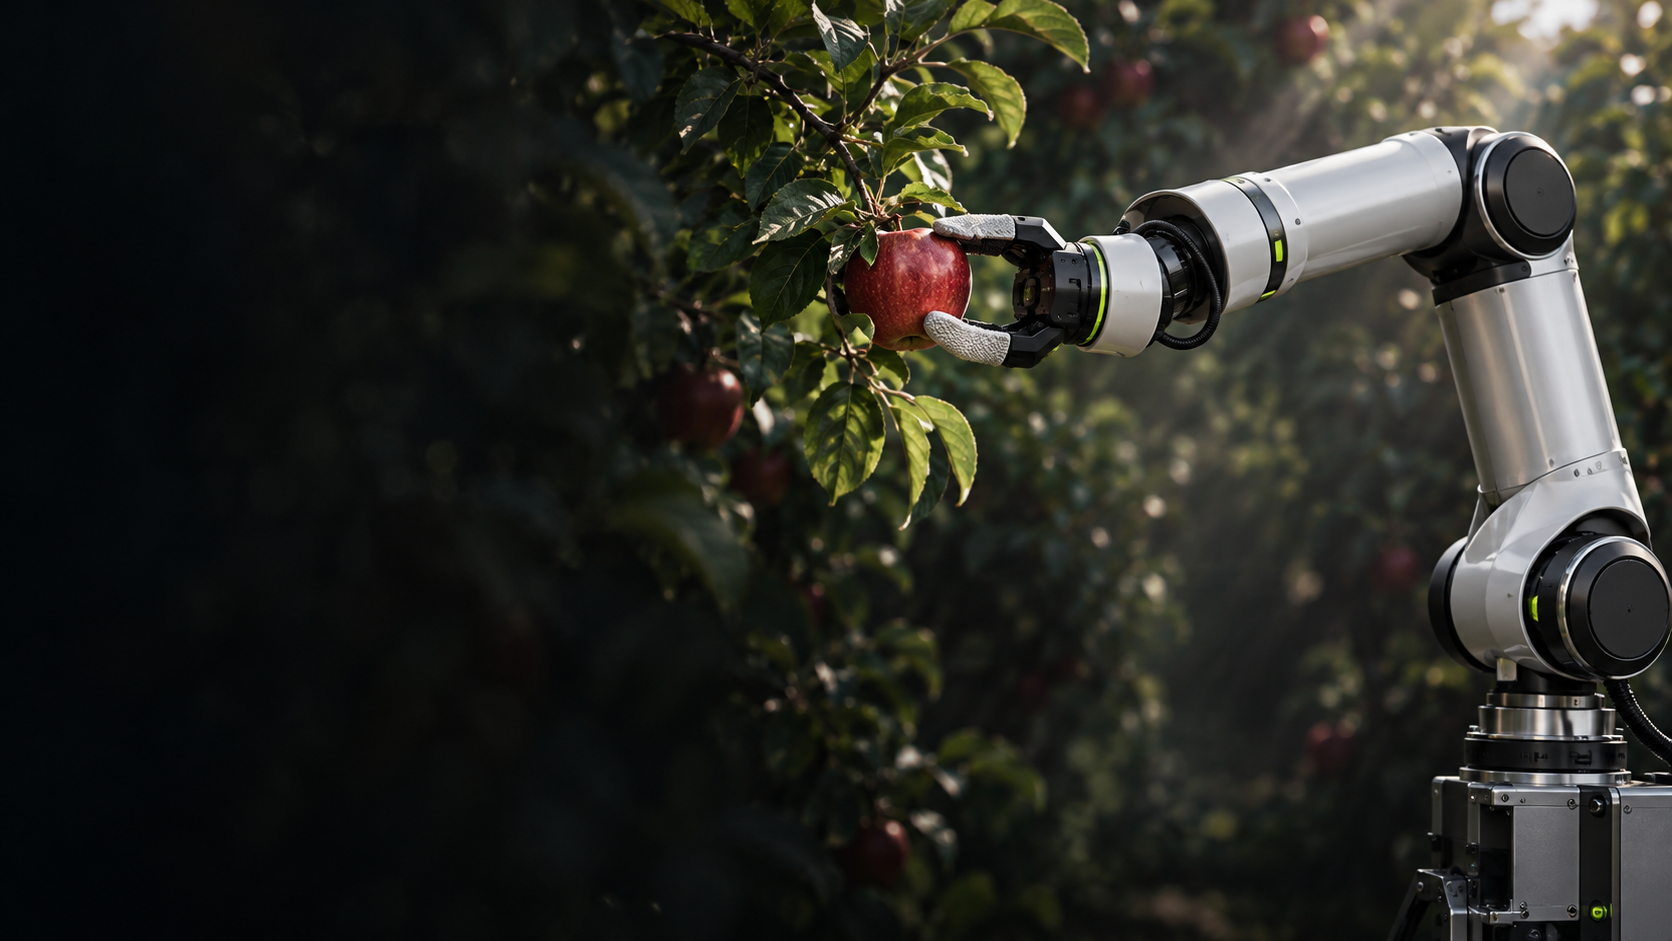
Soft contact and controlled motion guide our approach to end-effector design.
Bringing perception, precision and a gentle touch to the orchard. We’re developing robotic arms for the next generation of apple harvesting.
Discover our visionEvery apple is different.
So is every reach.
Branches move. Light changes. Fruit grows in unexpected places. Harvesting calls for intelligence that can see, adapt and interact with a living environment.
Our focus is selective apple harvesting: connecting visual understanding with controlled robotic movement, from the first observation to the final placement.
Understand fruit, branches and the space between them.
Plan a considered path through a changing environment.
Design every interaction around the fruit, not just the task.
Explore the four stages of our proposed harvesting loop.
Identify apples within the canopy and estimate their position. Build a spatial understanding of the fruit and surrounding branches before the arm moves.
Illustrative workflow. System under development; field performance is not yet validated.
Soft contact and controlled motion guide our approach to end-effector design.
Develop perception and planning together, with the variability of real orchards in mind.
Progress from concept to prototypes, then carefully designed orchard trials.
Starting with an apple.
Explore the technology